Robotics & Automation Engineer
Mohammed Salah Altaf Chogle
Final-year B.E. Automation & Robotics · VESIT, Mumbai
HARDWARE. FIRMWARE.
AUTONOMY.
- 1stRoboAnalyzer national final, IIT Delhi
- Top 30INVENTX R&D program, IIT Jammu
- PatentProvisional application filed, 2026
- 3Engineering internships
- 9.45CGPA, B.E. Automation & Robotics
ABOUT
"I build robotic systems end to end: PCBs and embedded firmware, desktop control software, ROS 2 autonomy and computer vision, taken from CAD to tested hardware."
PROJECT SPOTLIGHT
ADVANCED SAFE LOAD INDICATOR
BE capstone: a multi-sensor crane safety system on a custom 4-axis crane test rig, with ESP32 FreeRTOS firmware and a live dashboard.
ACADEMICS
CORE TECH STACK
CAREER & CURRICULUM
Explore Full CV
& Work Experience
FEATURED PROJECTS
F1TENTH Autonomous Racing Stack (ROS 2)
A hands-on ROS 2 learning implementation built on the official F1TENTH Gym simulator, progressing from safety braking (iTTC) and PID wall following to cubic spline raceline generation, pure pursuit, and multi-agent dynamic overtaking.
Advanced Safe Load Indicator (BE Capstone)
Final-year team capstone: an affordable, retrofittable Safe Load Indicator for small pick-and-carry cranes, built on a custom 4-axis crane test rig with load, angle, extension, outrigger and IMU sensing, ESP32 FreeRTOS firmware and a live dashboard.
Crane Health & Operator Monitoring System
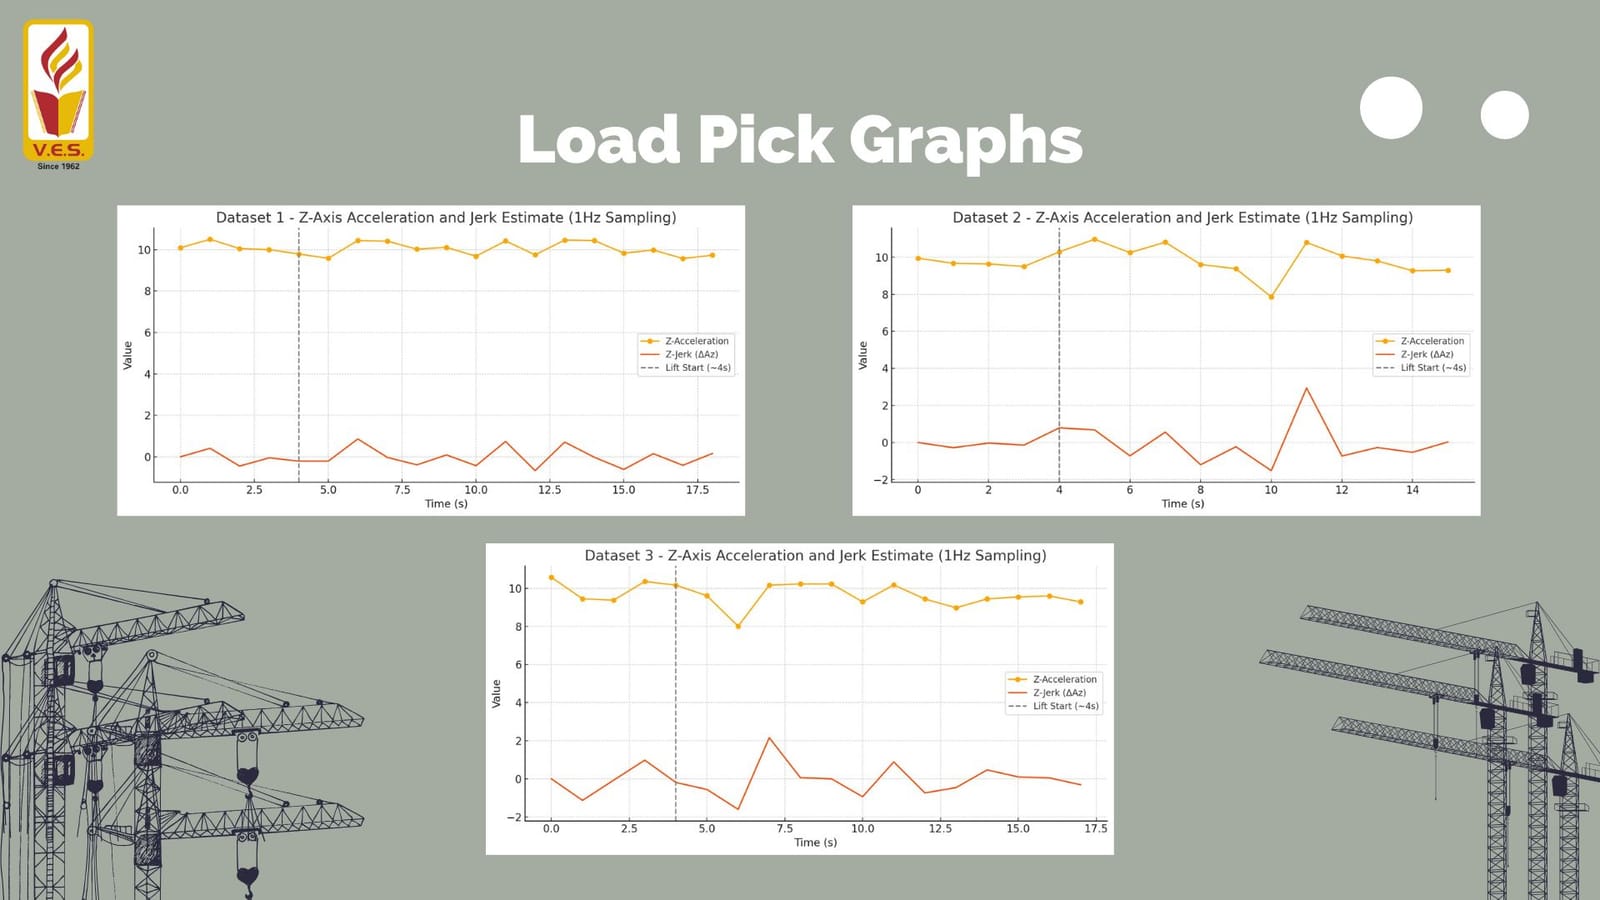
A dual-module crane monitoring system using MPU6050 IMU and ESP-NOW to track boom orientation, jerk magnitude, and lift duration for unsafe operation alerts and lift profile reconstruction.
VIEW ALL PROJECTS
All 12 projects: robot arms, autonomy, embedded and IoT builds
VIEW ALL →THE LAB
Embedded Systems & Microcontrollers
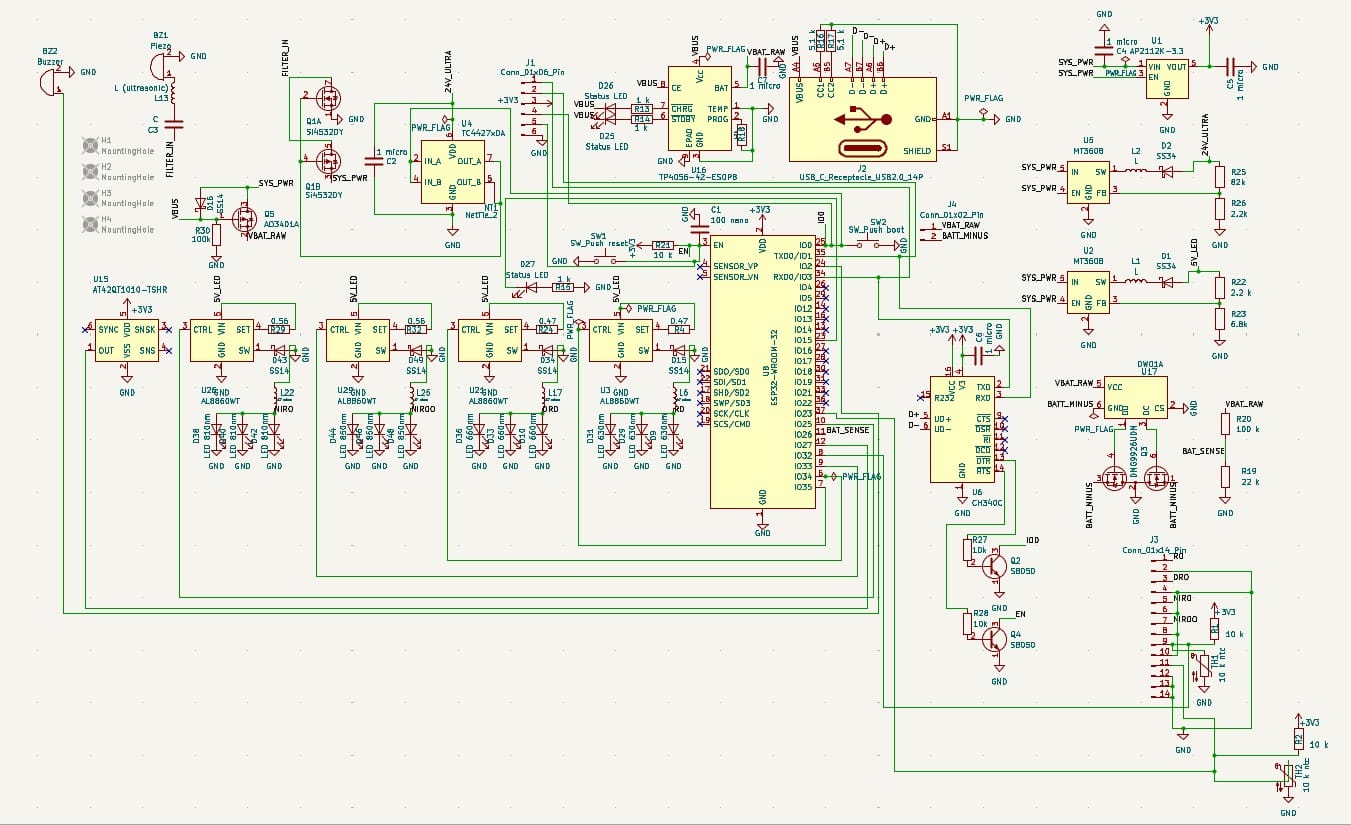
ESP32 and Arduino firmware, I2S/SPI/I2C/UART peripherals, ESP-NOW peer-to-peer links and sensor integration.
Robotics Software & GUI Control
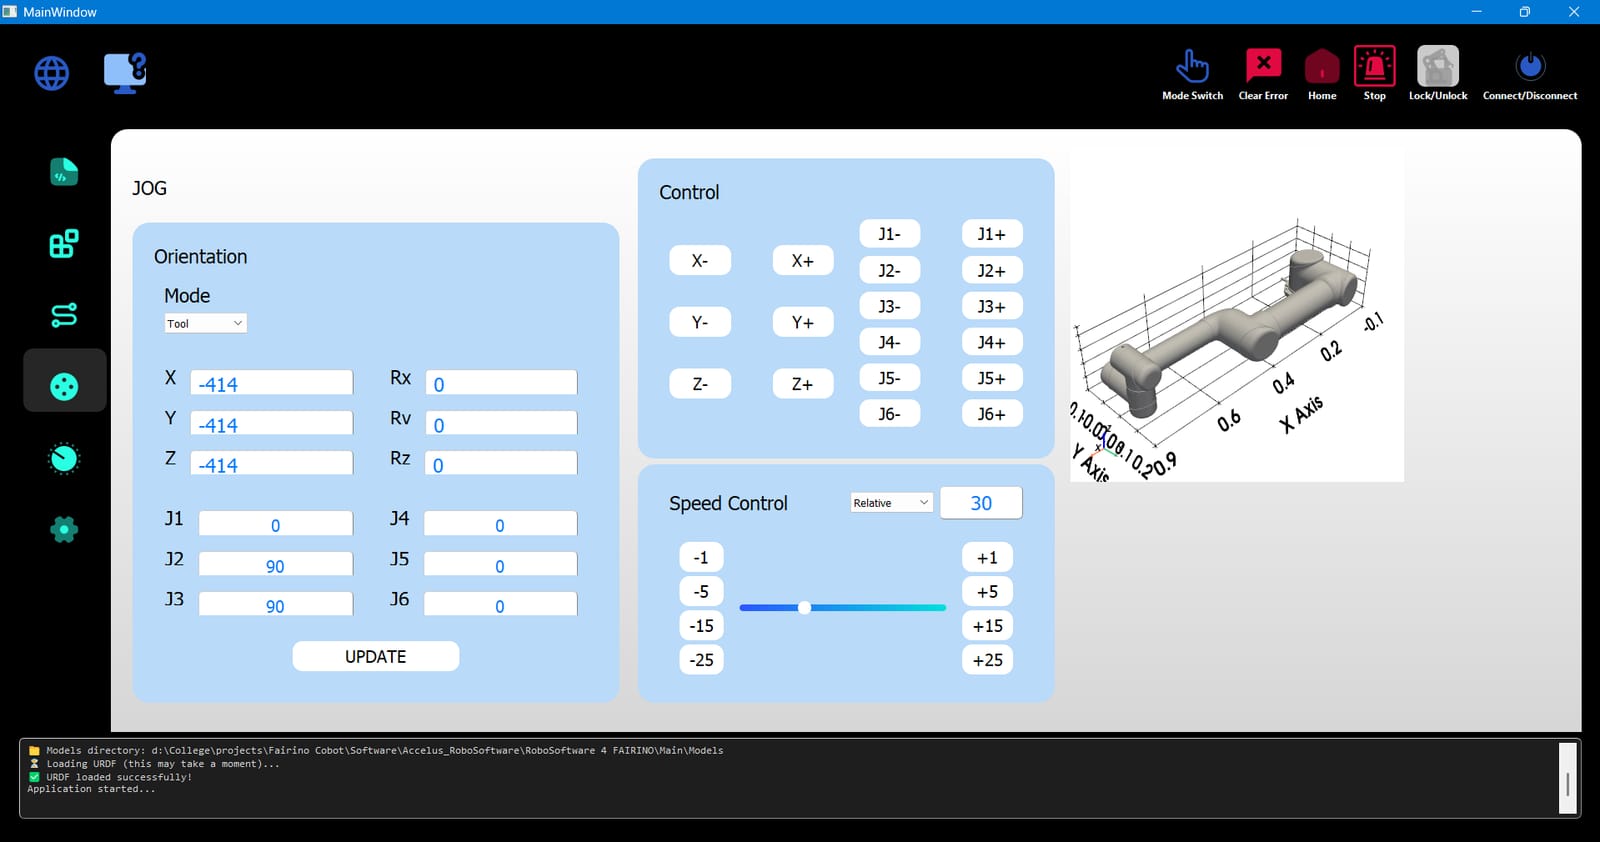
Desktop control interfaces, Blockly visual programming, URDF visualization and ROS 2.
Kinematics, Control & Computer Vision
Hand-gesture tracking with OpenCV and MediaPipe, inverse kinematics, cascade PID control and trajectory generation.
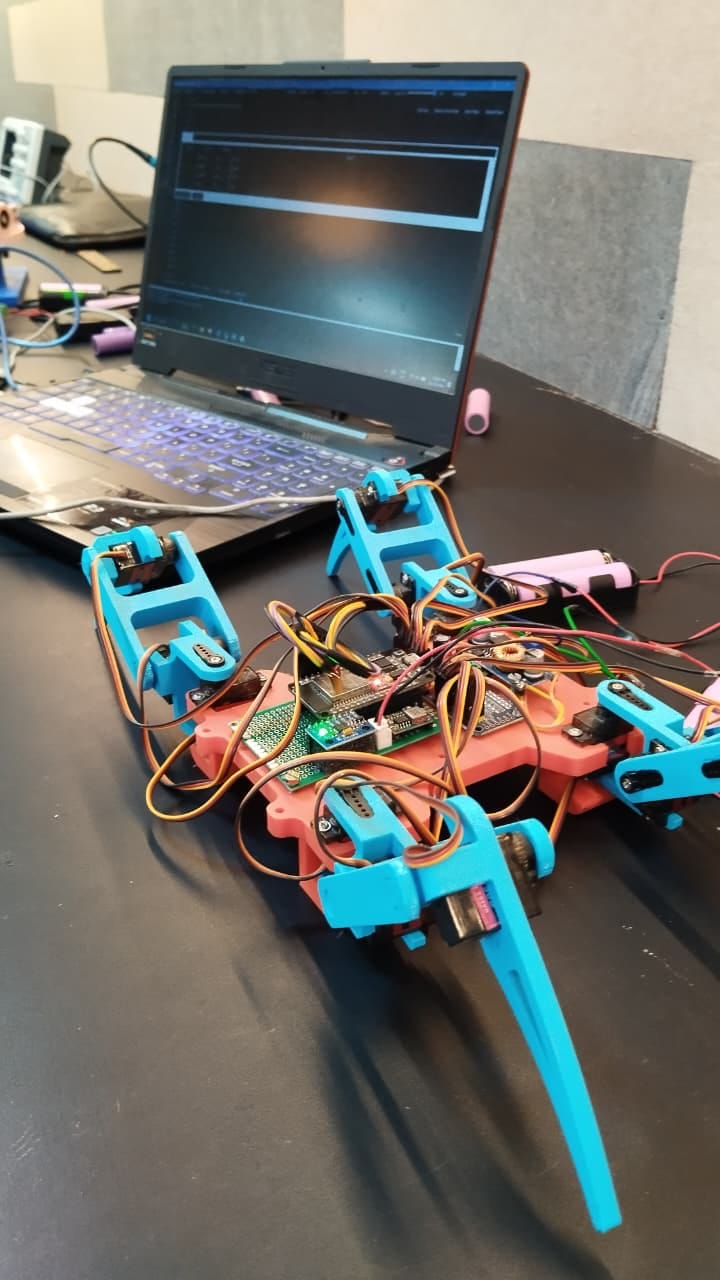
Rapid Prototyping, CAD & Mechanical Design
Fusion 360 modelling, FDM 3D printing, laser cutting, KiCad PCB layout and patent prior-art research.
3D parametric modeling, assemblies, 3D print prep
Schematics, multi-layer PCB layout & component routing
Computer vision joint tracking, image processing
Desktop robot control GUIs & custom dashboard integration
Slicing, FDM printer maintenance, mechanical enclosures
2D drafting, DXF manufacturing prep for laser cutters
3D modeling, asset visualization, rendering
Photoshop, Illustrator, After Effects, video editing
Robotics middleware concepts, nodes, topic messaging
Kinematics simulation, trajectory CSV generation
PyQt5 GUIs, OpenCV vision, NumPy math, robot SDK integration
Embedded C/C++, ESP32 and Arduino drivers and firmware
Servo driving, I2S audio, sensor polling, serial protocols
Application development & object-oriented programming
Kinematic calculations, matrix operations, control plots